
Motion#
Introduction#
The blue Motion cards drive and turn the robot, and spin the motor connected to port 3.
Below is a list of available cards:
drive 15 cm – Drives forward 15 centimeters (cm).
drive 30 cm – Drives forward 30 centimeters (cm).
drive 45 cm – Drives forward 45 centimeters (cm).
reverse 15 cm – Drives in reverse 15 centimeters (cm).
reverse 30 cm – Drives in reverse 30 centimeters (cm).
reverse 45 cm – Drives in reverse 45 centimeters (cm).
turn left 45° – Turns in place 45 degrees to the left.
turn left 90° – Turns in place 90 degrees to the left.
turn right 45° – Turns in place 45 degrees to the right.
turn right 90° – Turns in place 90 degrees to the right.
turn around 180° – Turns in place 180 degrees to the right.
turn random – Turns in place a random number of degrees.
drive until object – Drives forward until the Eye Sensor detects an object.
drive until pressed – Drives forward until the LED Bumper is pressed.
motor forward – Spins the motor connected to port 3 forward.
motor reverse – Spins the motor connected to port 3 in reverse.
motor slow – Sets the motor connected to port 3 to spin slowly.
motor stop – Stops the motor connected to port 3.
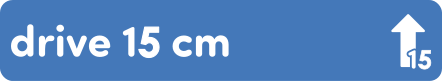
drive 15 cm#
The drive 15 cm card makes the robot drive forward 15 centimeters (cm).
Example
Drive forward 15 cm, turn right 90°, then drive forward 15 cm more.
drive 30 cm#
The drive 30 cm card makes the robot drive forward 30 centimeters (cm).
Example
Drive forward 30 cm, then glow the LED Bumper green.
drive 45 cm#
The drive 45 cm card makes the robot drive forward 45 centimeters (cm).
Example
Glow the LED Bumper green, then drive forward 45 cm.
reverse 15 cm#
The reverse 15 cm card makes the robot drive in reverse 15 centimeters (cm).
Example
Drive forward 15 cm, then reverse 15 cm back to where the robot started.
reverse 30 cm#
The reverse 30 cm card makes the robot drive in reverse 30 centimeters (cm).
Example
Drive up to an object, then back away 30 cm.
reverse 45 cm#
The reverse 45 cm card makes the robot drive in reverse 45 centimeters (cm).
Example
Drive forward 45 cm, wait 1 second, then reverse 45 cm.
turn left 45°#
The turn left 45° card makes the robot turn in place 45 degrees to the left.
Example
Turn left 45°, then drive forward 30 cm.
turn left 90°#
The turn left 90° card makes the robot turn in place 90 degrees to the left.
Example
Turn left 90°, then drive forward 15 cm.
turn right 45°#
The turn right 45° card makes the robot turn in place 45 degrees to the right.
Example
Turn right 45°, drive forward 15 cm, then turn left 45° to face the starting direction.
turn right 90°#
The turn right 90° card makes the robot turn in place 90 degrees to the right.
Example
Turn right 90° 4 times to spin all the way around.
turn around 180°#
The turn around 180° card makes the robot turn in place 180 degrees to the right from its starting position.
Example
Drive forward 30 cm, turn around, and drive back to where the robot started.
turn random#
The turn random card makes the robot turn in place a random number of degrees.
Example
Turn a random amount, then drive forward 30 cm.
drive until object#
The drive until object card makes the robot drive forward until the Eye Sensor detects an object. An object needs to be approximately 18 mm from the Eye Sensor to be detected.
Example
Drive up to an object, then turn around.
drive until pressed#
The drive until pressed card makes the robot drive forward until the LED Bumper is pressed and released.
Example
Drive forward until the LED Bumper is pressed, then reverse 15 cm.
motor forward#
The motor forward card spins the motor connected to port 3 forward. The motor keeps spinning until a motor stop card or another motor card runs. Motor cards and Magnet cards can’t be used in the same project, because the motor and the Electromagnet both connect to port 3.
Example
Spin the motor forward for 2 seconds, then stop it.
motor reverse#
The motor reverse card spins the motor connected to port 3 in reverse. The motor keeps spinning until a motor stop card or another motor card runs. Motor cards and Magnet cards can’t be used in the same project, because the motor and the Electromagnet both connect to port 3.
Example
Spin the motor forward for 1 second, then in reverse for 1 second, then stop it.
motor slow#
The motor slow card sets the speed of the motor connected to port 3 to slow. It does not spin the motor on its own. Any motor forward or motor reverse cards after it spin the motor slowly. Motor cards and Magnet cards can’t be used in the same project, because the motor and the Electromagnet both connect to port 3.
Example
Spin the motor forward for 2 seconds, then set it to slow and spin it forward for 2 more seconds to see the difference. Then, stop the motor.
motor stop#
The motor stop card stops the motor connected to port 3 from spinning. Motor cards and Magnet cards can’t be used in the same project, because the motor and the Electromagnet both connect to port 3.
Example
Spin the motor until the LED Bumper is pressed, then stop it.