
Time#
Introduction#
The gray Time cards control a focused amount of time for the robot to wait until the following action is executed. The wait until cards make the robot wait until the LED Bumper is pressed or the Eye Sensor detects an object.
Below is a list of available cards:
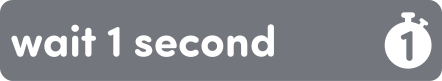
wait 1 second – Waits 1 second before moving on to the next card.
wait 2 seconds – Waits 2 seconds before moving on to the next card.
wait 4 seconds – Waits 4 seconds before moving on to the next card.
wait until pressed – Waits until the LED Bumper is pressed before moving on to the next card.
wait until object – Waits until the Eye Sensor detects an object before moving on to the next card.
wait 1 second#
The wait 1 second card makes the robot wait 1 second before moving on to the next Coder card in the project.
Example
Drive forward 15 cm, wait 1 second, then drive forward 15 cm more.
wait 2 seconds#
The wait 2 seconds card makes the robot wait 2 seconds before moving on to the next Coder card in the project.
Example
Glow the LED Bumper green for 2 seconds, then turn it off.

wait 4 seconds#
The wait 4 seconds card makes the robot wait 4 seconds before moving on to the next Coder card in the project.
Example
Glow the LED Bumper red, wait 4 seconds, then glow green.

wait until pressed#
The wait until pressed card makes the robot wait until the LED Bumper is pressed and released before moving on to the next Coder card in the project.
Example
Wait until the LED Bumper is pressed, then drive forward 30 cm.
wait until object#
The wait until object card makes the robot wait until the Eye Sensor detects an object before moving on to the next Coder card in the project.
Example
Wait until an object is in front of the robot, then glow the LED Bumper red.