
軸#
介紹#
axis 類別是 controller 類別的衍生類別。它提供對控制器操縱桿軸值和操縱桿軸更改回調的存取。
An axis object is accessed through a controller object. It is not constructed directly.
使用權#
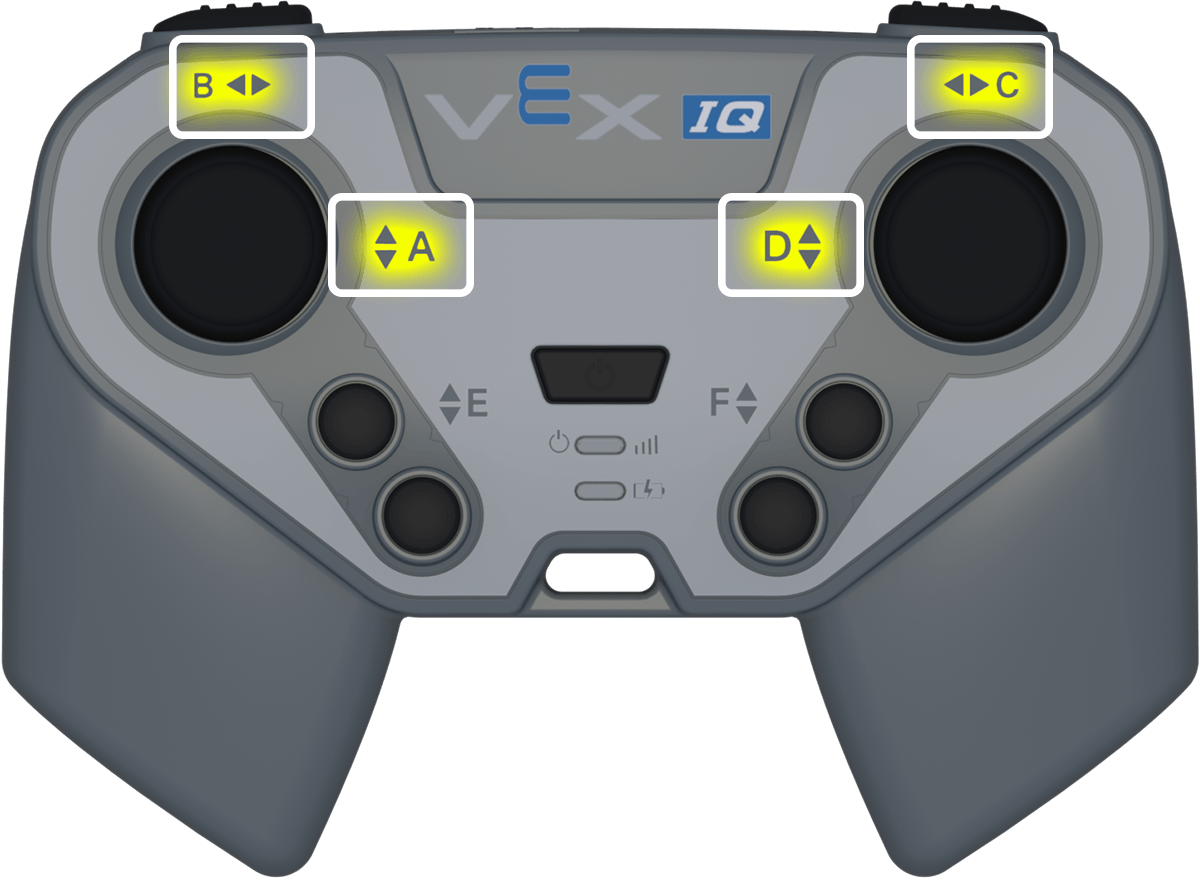
controller 類別提供以下軸物件。每個物件都是 axis 類別的一個實例。
軸對象 |
用法範例 |
描述 |
|---|---|---|
|
|
右搖桿水平軸。 |
|
|
右搖桿垂直軸。 |
|
|
左搖桿垂直軸。 |
|
|
左搖桿水平軸。 |
筆記#
在使用
axis成員函數之前,請建立一個controller物件。位置
position傳回的值介於-100到100之間。
// Create a controller object
controller Controller = controller();
成員功能#
axis 類別包含以下成員函數:
獲取器 — 讀取操縱桿軸位置。
position— 返回操縱桿軸的位置。
回呼函數-當搖桿沿著某個軸的位置改變時,執行一個函數。
changed— 當操縱桿的位置沿該軸改變時運行函數。
Getter#
position#
position 返回操縱桿軸的位置,值範圍為 -100 到 100。
可用功能
int32_t position(percentUnits units = percentUnits::pct) const;
範圍 |
類型 |
描述 |
|---|---|---|
|
|
可選。傳回的軸值所使用的單位。預設值為 |
傳回值
Returns an int32_t value from -100 to 100.
100— 操縱桿軸已完全朝正方向移動。0— 操縱桿軸居中。-100— 操縱桿軸完全向負方向移動。
例子
// Turn with the left joystick
while (true) {
  if (Controller.Axis4.position() > 10) {
    Drivetrain.turn(right);
  }
  else if (Controller.Axis4.position() < -10) {
    Drivetrain.turn(left);
  }
  else {
    Drivetrain.stop();
  }

  wait(20, msec);
}
打回來#
changed#
changed 當操縱桿的位置沿著該軸改變時運行一個函數。
可用功能
void changed(void (* callback)(void)) const;
範圍 |
類型 |
描述 |
|---|---|---|
|
|
每次操縱桿沿該軸位置變化時運行的函數。 |
範圍 |
類型 |
描述 |
|---|---|---|
|
|
預先定義的回調函數,當軸值改變時會自動呼叫。此函數必須符合所需的回呼函數簽章。有關更多信息,請參閱回調函數。 |
此函數不傳回值。
例子
在 main之外定義回呼函數。
定義回呼函數(在
int main()之外)// Play a sound when the left joystick moves void sounds() { Brain.playSound(siren); wait(1, seconds); }在
int main()中註冊回呼函數int main() { /* vexcodeInit() is only required when using VEXcode. Remove vexcodeInit() if compiling in VS Code. */ vexcodeInit(); // Call the function when the left joystick moves Controller.Axis4.changed(sounds); }