
객체 센서#
소개#
물체 센서는 반사된 적외선(IR) 빛을 이용하여 물체가 가까이 있을 때 이를 감지하는 적외선 근접 센서입니다.
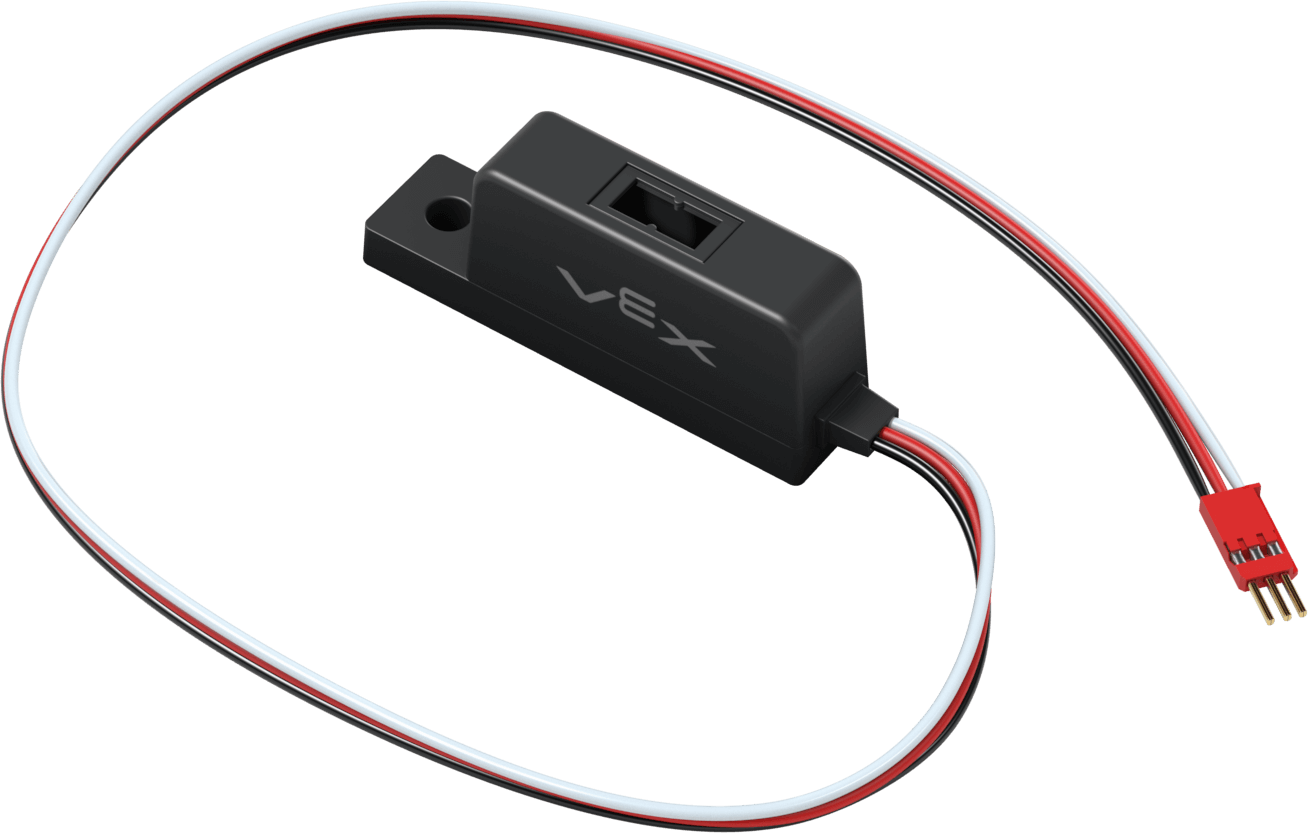
이 페이지에서는 예시 객체 센서 이름으로 object_sensor 사용합니다. 필요에 따라 구성된 이름으로 교체하십시오.
다음은 사용 가능한 방법 목록입니다.
reflectivity– 물체에서 반사되는 빛의 양을 백분율로 나타내는integer를 반환합니다.is_object_detected– 객체 센서가 객체를 감지하는지 여부를 반환합니다.set_threshold– 객체가 감지된 것으로 간주되기 전에 필요한 반사광의 양을 설정합니다.object_detected– 객체 센서가 새 객체를 감지할 때마다 호출될 함수를 등록합니다.object_lost– 객체 센서가 감지된 객체를 잃을 때마다 호출될 함수를 등록합니다.changed– 객체 센서의 값이 변경될 때마다 호출될 함수를 등록합니다.
생성자 – 객체 센서를 수동으로 초기화합니다.
ObjectDetector– 객체 센서를 생성합니다.
반사율#
reflectivity 물체에서 반사되는 빛의 양을 백분율로 나타내는 integer를 반환합니다.
메모:
반사율 0%는 물체가 매우 어둡다는 것을 의미합니다. 센서는 3000 이상의 원시 값을 감지합니다.
반사율 100%는 물체가 매우 밝다는 것을 의미합니다. 센서는 원시 값으로 0을 감지합니다.
Usage:
object_sensor.reflectivity()
매개변수 |
설명 |
|---|---|
이 메서드에는 매개변수가 없습니다. |
# Drive forward when the reflectivity is greater than 50%.
while True:
    if object_sensor.reflectivity() > 50:
        drivetrain.drive(FORWARD)
    else:
        drivetrain.stop()
    wait(5, MSEC)
객체가 감지되었습니다#
is_object_detected 객체 감지 센서가 객체를 감지했는지 여부를 반환합니다.
True– 객체 센서가 객체를 감지했습니다.False– 객체 센서가 객체를 감지하지 못했습니다.
Usage:
object_sensor.is_object_detected()
매개변수 |
설명 |
|---|---|
이 메서드에는 매개변수가 없습니다. |
# Drive forward when the object sensor is detecting an object.
while True:
    if object_sensor.is_object_detected():
        drivetrain.drive(FORWARD)
    else:
        drivetrain.stop()
    wait(5, MSEC)
임계값 설정#
set_threshold 은 물체가 감지된 것으로 간주되기 전에 필요한 반사광의 양을 백분율로 설정합니다.
Usage:
object_sensor.set_threshold(value)
매개변수 |
설명 |
|---|---|
|
물체를 감지한 것으로 간주하는 데 필요한 반사광의 양은 0에서 100 사이의 정수로 표현됩니다. |
# Set the reflectivity threshold to 50%.
object_sensor.set_threshold(50)
# Drive forward when the object sensor is detecting an object.
while True:
    if object_sensor.is_object_detected():
        drivetrain.drive(FORWARD)
    else:
        drivetrain.stop()
    wait(5, MSEC)
객체가 감지되었습니다#
object_detected 은 객체 센서가 새로운 객체를 감지할 때마다 호출될 함수를 등록합니다.
Usage:
object_sensor.object_detected(callback, arg)
매개변수 |
설명 |
|---|---|
|
객체 센서가 새 객체를 감지할 때 실행되는 이전에 정의된 함수입니다. |
|
선택 사항. 콜백 함수에 전달할 인수를 포함하는 |
def my_function():
  brain.screen.print("Object detected.")

# Call my_function whenever object_sensor detects an object
object_sensor.object_detected(my_function)
객체 손실#
object_lost 은 객체 센서가 감지된 객체를 놓칠 때마다 호출될 함수를 등록합니다.
Usage:
object_sensor.object_lost(callback, arg)
매개변수 |
설명 |
|---|---|
|
객체 센서가 감지된 객체를 놓쳤을 때 실행되는 이전에 정의된 함수. |
|
선택 사항. 콜백 함수에 전달할 인수를 포함하는 |
def my_function():
  brain.screen.print("Object lost.")

# Call my_function whenever object_sensor loses an object
object_sensor.object_lost(my_function)
변경됨#
changed 객체 센서의 값이 변경될 때마다 호출될 함수를 등록합니다.
Usage:
object_sensor.changed(callback, arg)
매개변수 |
설명 |
|---|---|
|
객체 센서의 값이 변경될 때 실행되는 이전에 정의된 함수입니다. |
|
선택 사항. 콜백 함수에 전달할 인수를 포함하는 |
def my_function():
  brain.screen.print("Reflectivity changed.")

# Call my_function whenever object_sensor's value changes
object_sensor.changed(my_function)
건설업자#
Constructors are used to manually create ObjectDetector objects, which are necessary for configuring Object Sensors.
ObjectDetector#
ObjectDetector 객체 센서를 생성합니다.
Usage:
ObjectDetector(port, reverse_det)
매개변수 |
설명 |
|---|---|
|
객체 센서가 연결된 3선 포트: |
|
선택 사항입니다. 감지 로직을 반전시킬지 여부:
|
# Create an Object Sensor in Port A
object_sensor = ObjectDetector(brain.three_wire_port.a)