
馬達控制器 55#
介紹#
馬達控制器 55 (MC55) 用於控制標準直流馬達。
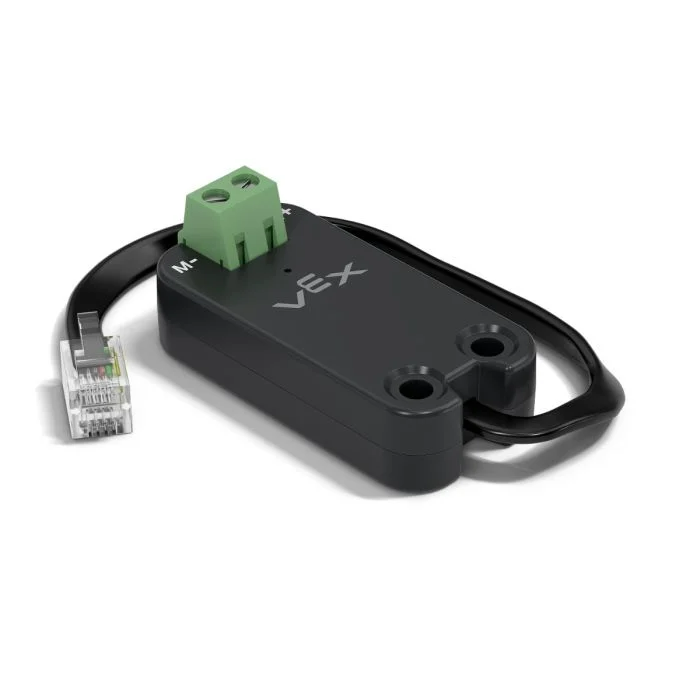
本頁使用 mc_55 作為範例馬達控制器 55 的名稱。請根據需要將其替換為您自己配置的名稱。
以下是可用方法清單:
spin– 使直流馬達正轉或反轉,直到停止。stop– 立即停止直流馬達。set_velocity– 告訴直流馬達旋轉的速度。set_stopping– 設定直流馬達停止時的行為。set_max_torque– 設定直流馬達允許使用的最大扭力。set_reversed– 設定直流馬達反轉其旋轉方向。current– 傳回直流馬達正在使用的電流大小。temperature– 返回直流馬達的溫度。
建構函式 - 手動初始化馬達控制器 55。
Motor55– 建立馬達控制器 55。
旋轉#
spin 使用 目前馬達轉速 使連接的直流馬達沿著指定方向旋轉。
Usage:
mc_55.spin(direction, velocity, units)
參數 |
描述 |
|---|---|
|
馬達旋轉方向:
|
|
Optional. The velocity to spin with from 0% to 100% when using |
|
Optional. The velocity unit:
|
# Spin the motor at -2 volts
mc_55.spin(FORWARD, -2)
停止#
stop 立即停止連接的直流電機,使用電流停止模式。
Usage:
mc_55.stop(mode)
範圍 |
描述 |
|---|---|
模式 |
Optional. The stopping behavior to use when the motor stops:
If the stopping mode is not specified or previously set, the default behavior is |
設定速度#
set_velocity 決定直流馬達的轉速。百分比越高,直流馬達轉速越快;百分比越低,直流馬達轉速越慢。
每個項目開始時,每個連接的直流馬達預設以 50% 的速度旋轉。
Usage:
mc_55.set_velocity(value, units)
範圍 |
描述 |
|---|---|
|
The velocity to spin with from 0% to 100% when using |
|
可選。速度單位: |
設定停止#
set_stopping 設定直流馬達停止時的行為。
Usage:
mc_55.set_stopping(mode)
參數 |
描述 |
|---|---|
|
How the motor will stop:
|
設定最大扭矩#
扭力表示直流馬達在旋轉時能夠產生的推力或拉力的大小。
set_max_torque 設定直流馬達允許使用的最大扭力。
Usage:
mc_55.set_max_torque(value, units)
參數 |
描述 |
|---|---|
|
The maximum torque the DC motor is allowed to use. This can be an |
|
可選。扭力單位: |
設定反轉#
set_reversed 將直流馬達反轉,使 FORWARD 方向順時針旋轉。此方法與建構 Motor55 時將 reverse 參數設為 True 效果相同。
Usage:
mc_55.set_reversed(value)
參數 |
描述 |
|---|---|
|
Whether the DC motor’s direction is reversed:
|
目前的#
current 返回直流馬達正在使用的電流大小,以安培為單位,範圍從 0.0 到 1.2 A。電流是指流過直流馬達的電量。
電流值越高,代表直流馬達消耗的電流越大。這種情況可能發生在直流馬達提升重物、推動物體或試圖在卡住時移動時。
這可以用來檢查直流馬達在運動過程中是否運轉吃力。如果電流持續過高,馬達可能會發熱或功率利用率降低。
Usage:
mc_55.current(units)
參數 |
描述 |
|---|---|
|
可選。目前單位: |
溫度#
temperature 返回直流馬達的溫度。
馬達溫度顯示直流馬達的溫度。溫度越高,表示直流馬達在工作過程中溫度越高。為了保持最佳性能,馬達溫度應保持在 55°C 以下。
如果直流馬達過熱,它會降低最大電流以保護自身。當溫度達到 70°C 時,馬達將停止運轉,直到冷卻。
這可以用來檢查直流馬達在重複運動、長時間運轉或推動物體時是否過熱。
Usage:
mc_55.temperature(units)
參數 |
描述 |
|---|---|
|
可選。溫度單位:
|
建構函數#
建構函式用於手動建立 Motor55 對象,這是在 VEXcode 之外配置 Motor Controller 55 所必需的。
Motor55#
Motor55 創建馬達控制器 55。
Usage:
Motor55(port, reverse)
範圍 |
描述 |
|---|---|
|
The 3-Wire Port that the motor controller is connected to:
|
|
Optional. Sets whether the motor’s spin should be reversed.
|
# Create a Motor Controller 55 in Port A
mc_55 = Motor55(brain.three_wire_port.a)