
距離計#
導入#
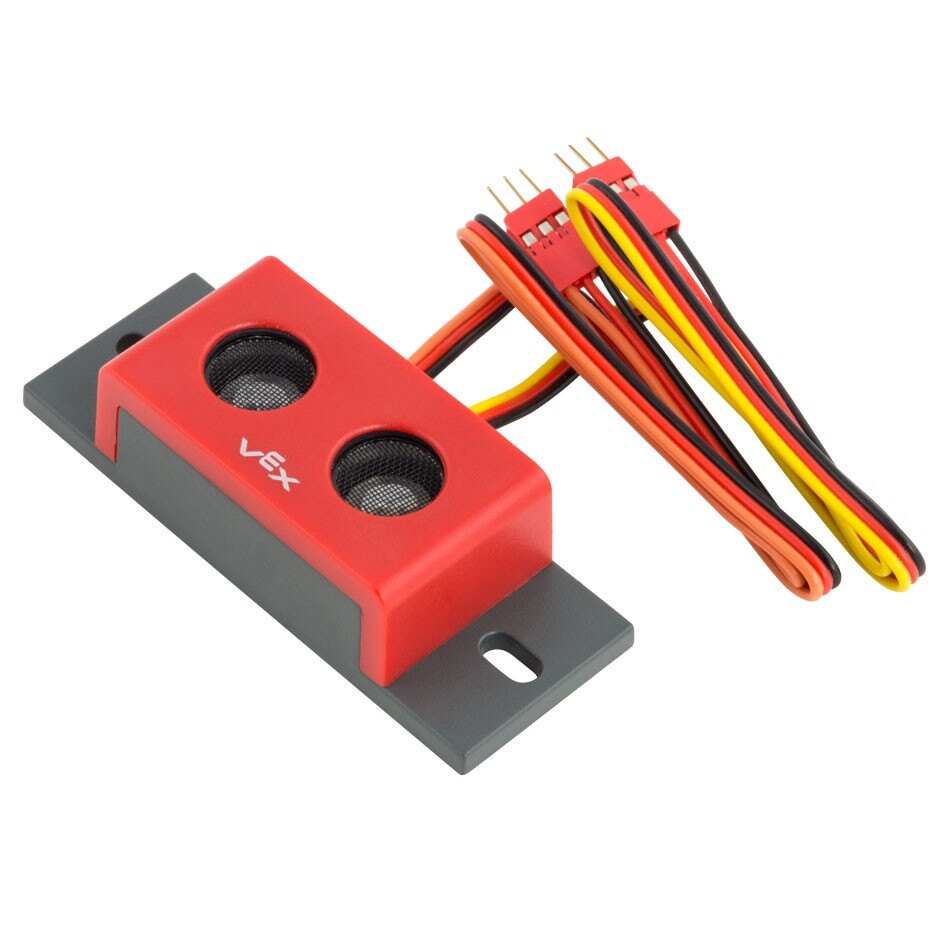
sonar クラスは、超音波距離計で使用され、音波を用いて最も近い物体までの距離を測定します。超音波パルスを発信し、音が反射して戻ってくるまでの時間を測定することで機能します。
クラスコンストラクタ#
sonar(
  triport::port &port);
クラスデストラクタ#
sonar オブジェクトを破壊し、関連するリソースを解放します。
virtual ~sonar();
パラメータ#
パラメータ |
タイプ |
説明 |
|---|---|---|
|
|
レンジファインダーで使用される必須の 2 ポート グループの最初の 3 線ポート。レンジファインダーは、ブレインまたは 3 線エキスパンダー上の 2 つの隣接するポート (A–B、C–D、E–F、または G–H) を占有します。ペアの最初のポート (A、C、E、または G) を |
例#
// Create a sonar instance in Ports A and B
sonar RangeFinderA = sonar(Brain.ThreeWirePort.A);
メンバーの機能#
sonar クラスには、以下のメンバ関数が含まれています。
foundObject— レンジファインダーがオブジェクトを検出したかどうかを返します。distance— レンジファインダーと最も近い検出対象物との間の距離を返します。
sonar メンバー関数を呼び出す前に、以下に示すように sonar インスタンスを作成する必要があります。
/* This constructor is required when using VS Code.
Range Finder configuration is generated automatically
in VEXcode using the Device Menu. Replace the values
as needed. */

// Create a sonar instance in Ports A and B
sonar RangeFinderA = sonar(Brain.ThreeWirePort.A);
foundObject#
レンジファインダーが視野内に物体を検出したかどうかを返します。
Available Functionsbool foundObject();
この関数は引数を受け付けません。
Return Valuesレンジファインダーがオブジェクトを検出したかどうかを表すブール値 bool を返します。
true— 距離計が物体を検出しています。false— 距離計が物体を検出していません。
// Check if an object is detected.
if (RangeFinderA.foundObject()){
    // Print to screen on the brain that an object was found.
    Brain.Screen.print("object found");
}
distance#
センサーが検出した最も近い物体までの測定距離を返します。
Available Functionsdouble distance(
distanceUnits units );
パラメータ |
タイプ |
説明 |
|---|---|---|
|
|
距離を表す単位: |
指定された単位での距離を表す double を返します。
// Get the Range Finder distance in millimeters.
double value = RangeFinderA.distance(mm);

// Print the current distance detected by the Range Finder to the
// Brain's screen.
Brain.Screen.print(value);