Turning Your Robot#
Turning Your Robot
This tutorial walks you through using the turn for block to turn your robot in VEXcode GO. By the end, you’ll have a project that turns your robot around.
Make sure your robot is configured with a Drivetrain, so you see the Drivetrain blocks in the toolbox. See Configuring Devices if you haven’t added one yet.
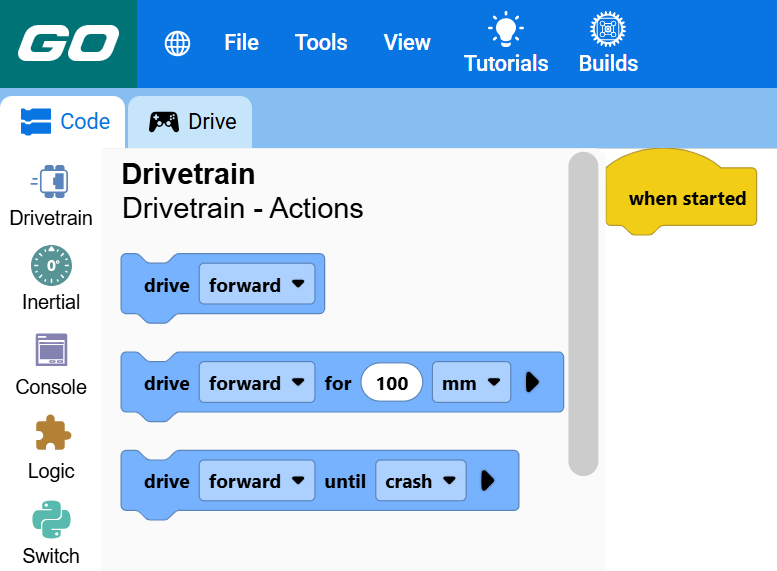
Attach a turn for block below the when started block.
A turn for block connected below when started.#
    when started :: hat events
        turn [right v] for (90) degrees ▶
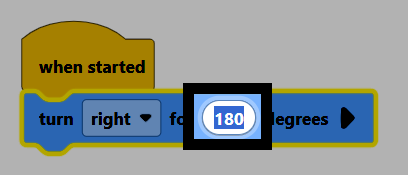
Change the angle parameter to 180.
Make sure your robot is connected to VEXcode, then select Start to run the project. The robot will turn around to face the opposite direction.