
コンソール#
導入#
VEXcode GOコンソールは、VEXcode内のコンソールタブに表示されます。コンソールメソッドを使用すると、プロジェクトの実行中にテキスト、数値、変数値を表示できます。また、コンソールカーソルを新しい行に移動したり、コンソールをクリアしたり、ユーザー入力を読み取ったり、色の変更後に表示されるテキストの色を設定したり、VEXcodeのモニタータブで変数やセンサー値を監視したりすることもできます。
以下にすべてのメソッドの一覧を示します。
アクション — テキストを出力するか、コンソールをクリアします。
ゲッター — ユーザー入力を読み取る。
input— ユーザー入力を待ち、応答をテキストとして返します。
ミューテーター — 印刷テキストの書式設定。
set_print_color— コンソールに表示されるテキストの色を設定します。
モニター — VEXcodeのモニタータブで、プロジェクト中にセンサーまたは変数の値を監視します。
monitor_sensor— モニター タブに 1 つ以上のセンサー値を追加します。monitor_variable— 1 つ以上の定義済み変数をモニター タブに追加します。
行動#
print#
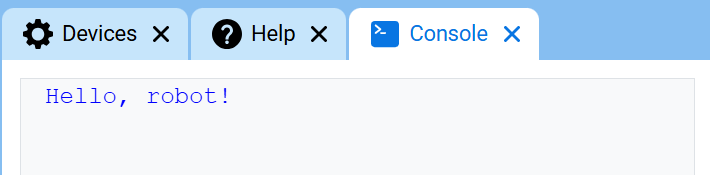
print は、現在のカーソル位置を使用してコンソールにテキスト、数値、または変数値を表示します。
印刷メッセージに、スコア、タイマー、センサーの読み取り値など、プロジェクトの値を含める場合は、カスタム文字列フォーマットを使用します。詳細については、文字列フォーマットページを参照してください。
次の印刷値を新しい行から開始したい場合は、new_line を使用します。
Usage:
console.print(value, precision)
パラメータ |
説明 |
|---|---|
|
コンソールに表示するテキスト、数値、または変数値。 |
|
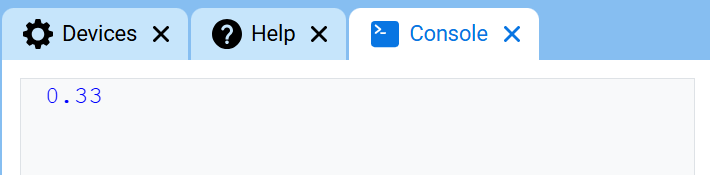
オプション。数値を印刷する際に表示する小数点以下の桁数を指定します。デフォルトは |
def main():
    # Display a message in the Console
    console.print("Hello, robot!")

# Start threads — Do not delete
start_thread(main)
def main():
    # Display 1/3 with two decimals
    console.print(1 / 3, precision=2)

# Start threads — Do not delete
start_thread(main)
new_line#
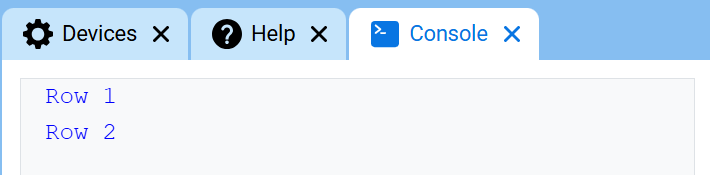
new_line コンソールの次の行の 1 列目にカーソルを移動します。次に表示される値はその行に表示されます。
次の印刷値を新しい行から開始したい場合は、この方法を使用してください。
Usage:
console.new_line()
パラメータ |
説明 |
|---|---|
このメソッドにはパラメータがありません。 |
def main():
    # Print on two lines
    console.print("Row 1")
    console.new_line()
    console.print("Row 2")

# Start threads — Do not delete
start_thread(main)
clear#
clear コンソールからすべての行をクリアします。
Usage:
console.clear()
パラメータ |
説明 |
|---|---|
このメソッドにはパラメータがありません。 |
def main():
    # Display text, then clear it after two seconds
    console.print("This will disappear...")
    wait(2, SECONDS)
    console.clear()

# Start threads — Do not delete
start_thread(main)
ゲッター#
input#
input は、ユーザーが応答を入力するのを待ち、その応答をテキストとして返します。
プロジェクトは、コンソールに応答が入力されるまで、 input() で一時停止します。
input() によって返される値は常にテキストです。応答を数値として使用するには、まず int() または float()で変換してください。
Usage:
input()
パラメータ |
説明 |
|---|---|
このメソッドにはパラメータがありません。 |
# Ask for a name, then print a greeting
answer = input("What's your name?")
console.print("Hello, " + answer)
# Ask for a number, then use it in math
answer = input("Enter a number:")
number = float(answer)
console.print(number + 1)
ミューテーター#
set_print_color#
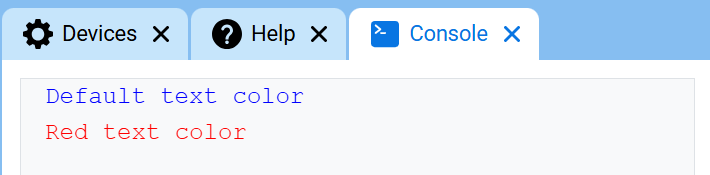
set_print_color このメソッドが使用された後にコンソールに表示されるテキストの色を設定します。プロジェクトの開始時には、コンソールのテキストの色は BLUEに設定されます。
Usage:
console.set_print_color(color)
パラメータ |
説明 |
|---|---|
|
コンソールに表示されるテキストの色:
|
def main():
    # Print text in different colors
    console.print("Default text color")
    console.new_line()
    console.set_print_color(RED)
    console.print("Red text color")

# Start threads — Do not delete
start_thread(main)
モニター#
monitor_sensor#
monitor_sensor は、VEXcode のモニター タブに 1 つ以上のセンサー値を追加します。これにより、プロジェクトの実行中にセンサー値の変化を監視できます。
各センサー値を文字列として指定してください。
Usage:
monitor_sensor(“sensor”)
monitor_sensor(“sensor1”, “sensor2”)
パラメータ |
説明 |
|---|---|
|
The sensor value to monitor, given as a string. To monitor more than one sensor value, separate each sensor value with a comma. Options include:
|
# Build Used: Super Code Base 2.0
def main():
    # Monitor the rotation in the Monitor tab
    monitor_sensor("drivetrain.get_rotation")
    drivetrain.turn_for(RIGHT, 450)

# Start threads — Do not delete
start_thread(main)
# Build Used: Super Code Base 2.0
def main():
    # Monitor the rotation and heading in the Monitor tab
    monitor_sensor("drivetrain.get_rotation", "drivetrain.get_heading")
    drivetrain.turn_for(RIGHT, 450)

# Start threads — Do not delete
start_thread(main)
monitor_variable#
monitor_variable 、VEXcode のモニター タブに 1 つ以上の定義済み変数を追加します。これにより、プロジェクトの実行中に変数の値の変化を監視できます。
変数を正常に監視するには monitor_variable グローバルである必要があります。各変数名は文字列として指定してください。
Usage:
monitor_variable(“variable”)
monitor_variable(“variable1”, “variable2”)
パラメータ |
説明 |
|---|---|
|
監視対象となる定義済みグローバル変数の名前を文字列で指定します。複数の変数を監視する場合は、各変数名をカンマで区切ってください。 |
# Build Used: Super Code Base 2.0
def main():
    # Monitor the amount of loops
    global loops
    monitor_variable("loops")

    # Drive in a square 3 times
    for loops in range(12):
        drivetrain.turn_for(RIGHT, 90, DEGREES)
        drivetrain.drive_for(FORWARD, 150, MM)

# Start threads — Do not delete
start_thread(main)
actions = 0

# Build Used: Super Code Base 2.0
def main():
    # Monitor the amount of loops and actions
    global loops, actions
    monitor_variable("loops", "actions")

    # Drive in a square 3 times
    for loops in range(12):
        drivetrain.turn_for(RIGHT, 90, DEGREES)
        drivetrain.drive_for(FORWARD, 150, MM)
        actions = actions + 2

# Start threads — Do not delete
start_thread(main)