
線路追蹤器#
介紹#
循線器是一種類比感測器,它利用紅外線LED和光感測器來檢測前方表面的反射率。它設計用於安裝在機器人底盤下方,使機器人能夠沿著預先標記的路徑行進。
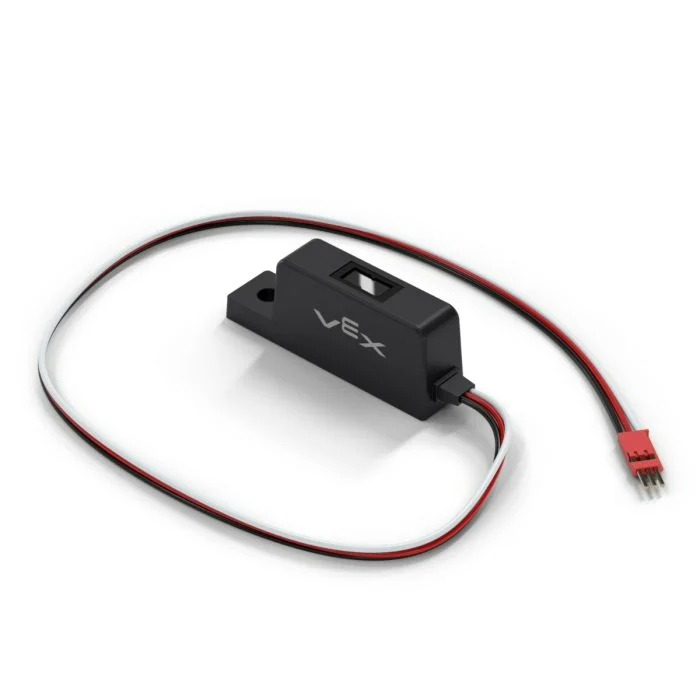
本頁面使用 line_tracker 作為範例線路追蹤器名稱。請根據需要將其替換為您自己配置的名稱。
以下是可用方法清單:
reflectivity– 回傳一個integer,表示從表面反射的光量,以百分比表示。
建構函式 – 手動初始化線路追蹤器。
Line– 建立行追蹤器。
反射率#
reflectivity 回傳一個 integer,表示表面反射光量的百分比。這可用於幫助機器人沿著預先標記的路徑行進。
筆記:
0%反射率意味著物體非常暗。
100%反射率意味著物體非常明亮。
Usage:
line_tracker.reflectivity(units)
範圍 |
描述 |
|---|---|
|
可選。傳回反射率的單位: |
建構函數#
建構函式用於手動建立 Line 對象,這是在 VEXcode 之外配置 Line Tracker 所必需的。
Line#
Line 行建立行追蹤器。
Usage:
Line(port)
範圍 |
描述 |
|---|---|
|
The 3-Wire Port that the Line Tracker is connected to:
|
# Create a Line Tracker in Port A
line_tracker = Line(brain.three_wire_port.a)