
伺服馬達#
介紹#
VEX 三線伺服馬達 是一款三線設備,可根據 V5 控制器的控制訊號旋轉到特定位置。
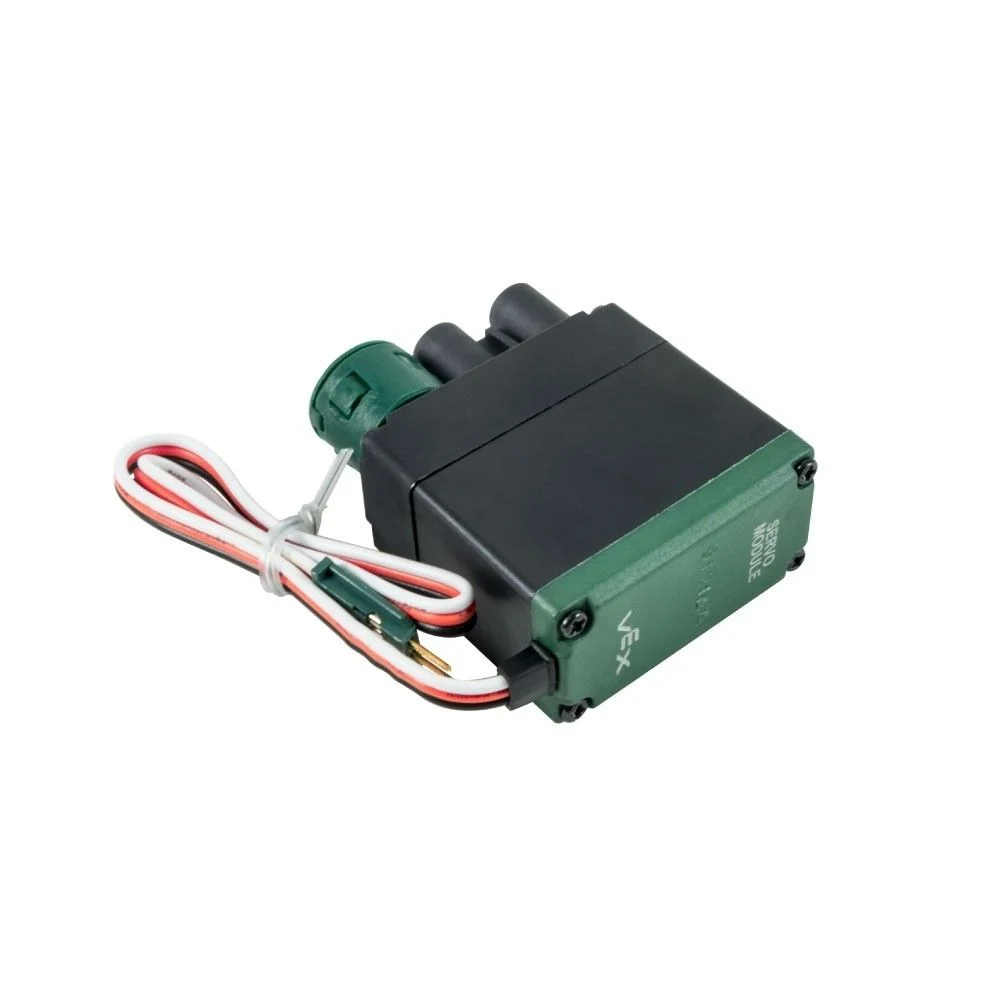
本頁使用 servo_motor 作為範例伺服馬達名稱。請根據需要將其替換為您自己配置的名稱。
以下是可用方法清單:
set_position– 將伺服馬達移到 0 到 100 度之間的指定位置。
建構函式 - 手動初始化伺服馬達。
Servo– 建立一個伺服馬達。
設定位置#
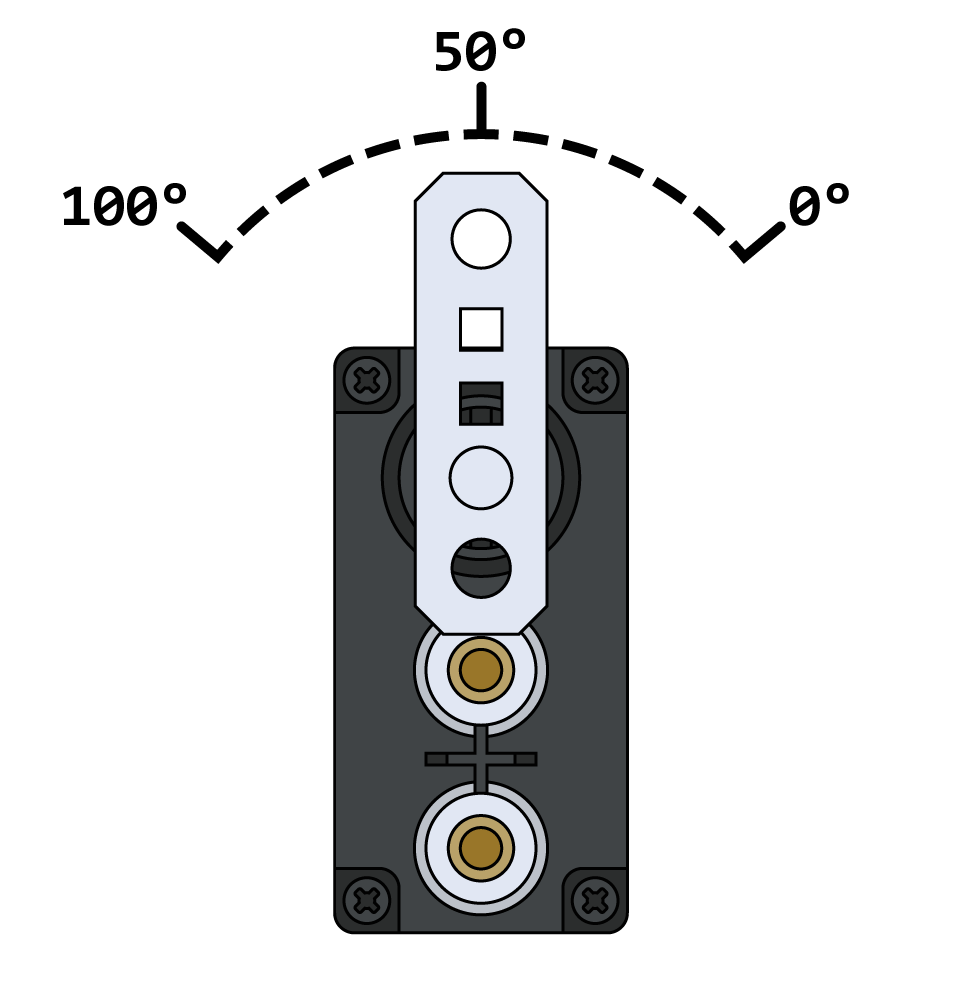
set_position 將伺服馬達移到 0 到 100 度之間的指定位置。
注意:伺服馬達在開始每個項目之前,都會自動將自身居中於 50 度,然後再進行任何運動。
Usage:
servo_motor.set_position(value, units)
參數 |
描述 |
|---|---|
|
The position value to set for the Servo Motor. This can be an |
|
位置單位: |
建構函數#
建構函數用於手動建立 Servo 對象,這是在 VEXcode 之外配置伺服馬達所必需的。
Servo#
Servo 創建一個伺服馬達。
Usage:
Servo(port)
範圍 |
描述 |
|---|---|
|
The 3-Wire Port that the Servo Motor is connected to:
|
# Create a Servo Motor in Port A
servo_motor = Servo(brain.three_wire_port.a)