
Σερβοκινητήρας#
Εισαγωγή#
Ο 3-wire Servo Motor VEX είναι μια συσκευή 3-wire που μπορεί να περιστραφεί σε μια συγκεκριμένη θέση με βάση ένα σήμα ελέγχου από τον EXP Brain.
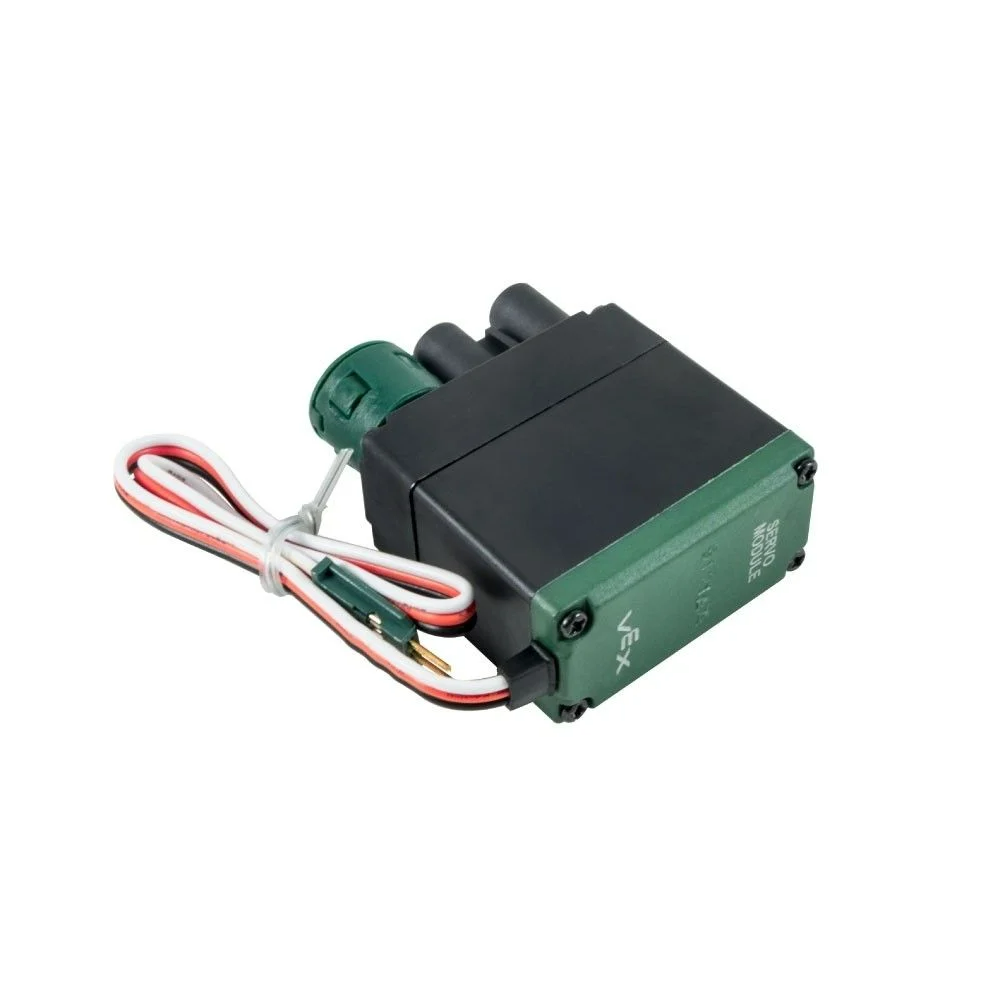
This page uses servo_motor as the example Servo Motor name. Replace it with your own configured name as needed.
Παρακάτω είναι μια λίστα με τις διαθέσιμες μεθόδους:
set_position– Moves a Servo Motor to a specified position between 0 and 100 degrees.
Κατασκευαστής – Χειροκίνητη αρχικοποίηση ενός σερβοκινητήρα.
Servo– Creates a Servo Motor.
ορισμός_θέσης#
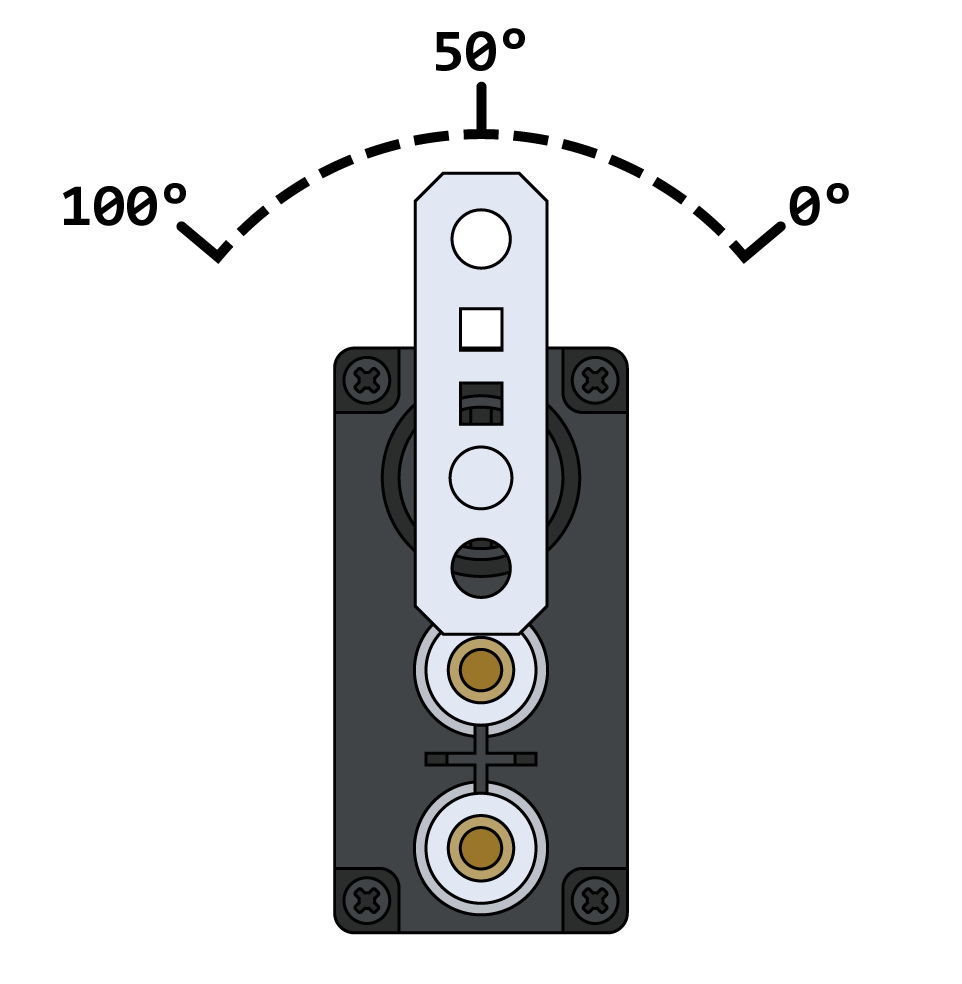
set_position moves a Servo Motor to a specified position between 0 and 100 degrees.
Σημείωση: Ένας σερβοκινητήρας ξεκινά κάθε έργο κεντράροντας αυτόματα στις 50 μοίρες πριν ολοκληρώσει οποιαδήποτε κίνηση.
Usage:
servo_motor.set_position(value, units)
Παράμετροι |
Περιγραφή |
|---|---|
|
The position value to set for the Servo Motor. This can be an |
|
The position unit: |
Κατασκευαστές#
Constructors are used to manually create Servo objects, which are necessary for configuring a Servo Motor outside of VEXcode.
Servo#
Servo creates a Servo Motor.
Usage:
Servo(port)
Παράμετρος |
Περιγραφή |
|---|---|
|
The 3-Wire Port that the Servo Motor is connected to:
|
# Create a Servo Motor in Port A
servo_motor = Servo(brain.three_wire_port.a)