
馬達 393(馬達控制器 29)#
介紹#
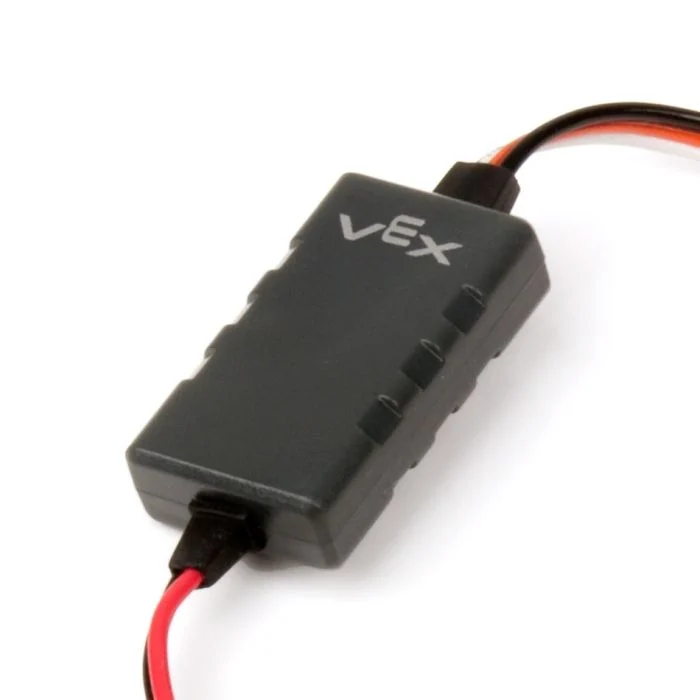
motor29 類別用於控制連接到 3 線連接埠 的馬達控制器 29。馬達控制器 29 發送來自 EXP 大腦的 PWM 訊號來驅動 VEX 馬達 393。
類別建構函數#
1 — 在指定的 3 線連接埠上建立一個
motor29物件。motor29( triport::port &port );
2 — 在指定的 3 線連接埠上建立一個
motor29對象,並改變正向旋轉方向。motor29( triport::port &port, bool reverse );
類別析構函數#
銷毀 motor29 物件並釋放相關資源。
~motor29();
參數#
範圍 |
類型 |
描述 |
|---|---|---|
|
|
馬達控制器 29 連接的 3 線端口,寫成 |
|
|
Sets whether the motor’s spin direction is reversed:
|
例子#
// Create a Motor Controller 29 instance in 3-Wire Port A
motor29 Motor393_A = motor29(
    Brain.ThreeWirePort.A );
成員功能#
motor29 類別包含下列成員函數:
旋轉 — 使馬達沿指定方向旋轉。
停止 — 停止馬達。
setVelocity — 告訴馬達 393 旋轉的速度。
setReversed — 設定馬達的旋轉方向是否反轉。
在呼叫 motor29 成員函數之前,必須先建立一個實例,如下所示:
/* This constructor is required when using VS Code.
Motor 393 configuration is generated automatically
in VEXcode using the Device Menu. Replace the values
as needed. */

// Create a Motor Controller 29 instance in 3-Wire Port A
motor29 Motor393_A = motor29(
    Brain.ThreeWirePort.A );
spin#
使馬達 393 沿指定方向無限旋轉。
可用功能
1 — 使用 目前配置的速度 旋轉。
void spin(
 directionType dir );
2 — 以指定速度旋轉。
void spin(
 directionType dir,
 double        velocity,
 velocityUnits units );
參數
範圍 |
類型 |
描述 |
|---|---|---|
|
|
馬達旋轉方向: |
|
|
當使用 |
|
|
速度單位:
|
傳回值
此函數不傳回值。
條筆記
函數不等待,呼叫後項目將立即繼續執行。
馬達 393 將繼續旋轉,直到呼叫
stop或使用另一個spin。
stop#
停止馬達運轉。
可用功能
void stop();
參數
此函數不接受任何參數。
傳回值
此函數不傳回值。
setVelocity#
告訴馬達 393 旋轉的速度。百分比越高,馬達 393 旋轉越快;百分比越低,馬達 393 旋轉越慢。
每個項目開始時,每個馬達 393 預設以 50% 的速度旋轉。
可用功能
void setVelocity(
    double velocity,
    percentUnits units );
參數
範圍 |
類型 |
描述 |
|---|---|---|
|
|
當使用 |
|
|
速度單位: |
傳回值
此函數不傳回值。
setReversed#
設定是否反轉馬達的旋轉方向。
可用功能
void setReversed(
    bool value );
參數
範圍 |
類型 |
描述 |
|---|---|---|
|
|
馬達 393 的旋轉方向是否反轉:
|
傳回值
此函數不傳回值。
條筆記
呼叫
setReversed與更改 建構子 中的reverse參數相同。