Moving the Arm#
Moving the Arm
This tutorial covers how to move the arm on your VEX IQ Clawbot in VEXcode IQ (2nd gen). By the end, you’ll have a project that raises the arm.
Make sure your robot is configured with the Drivetrain, Claw + Arm Motors version of the Clawbot build, so you see the ClawMotor and ArmMotor blocks in the toolbox.
Attach the spin motor for block to the when started block.
The spin motor for block, spinning the ClawMotor by default.#
    when started
        spin [ClawMotor v] [close v] for (90) [degrees v] ▶
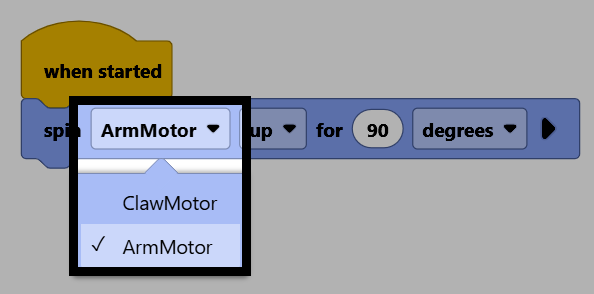
Change its motor parameter to ArmMotor, to control the arm.
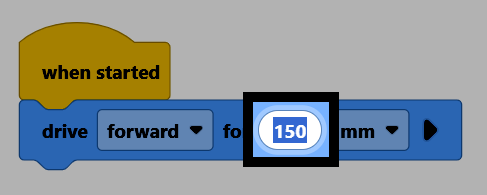
Change its distance parameter to 180, to move the arm 180 degrees from its current position.
Make sure your robot is connected to VEXcode, then select Download to download the project to the Brain.
Select Run to run the project. This project will now raise the arm up.